Subject
Micromouse Design
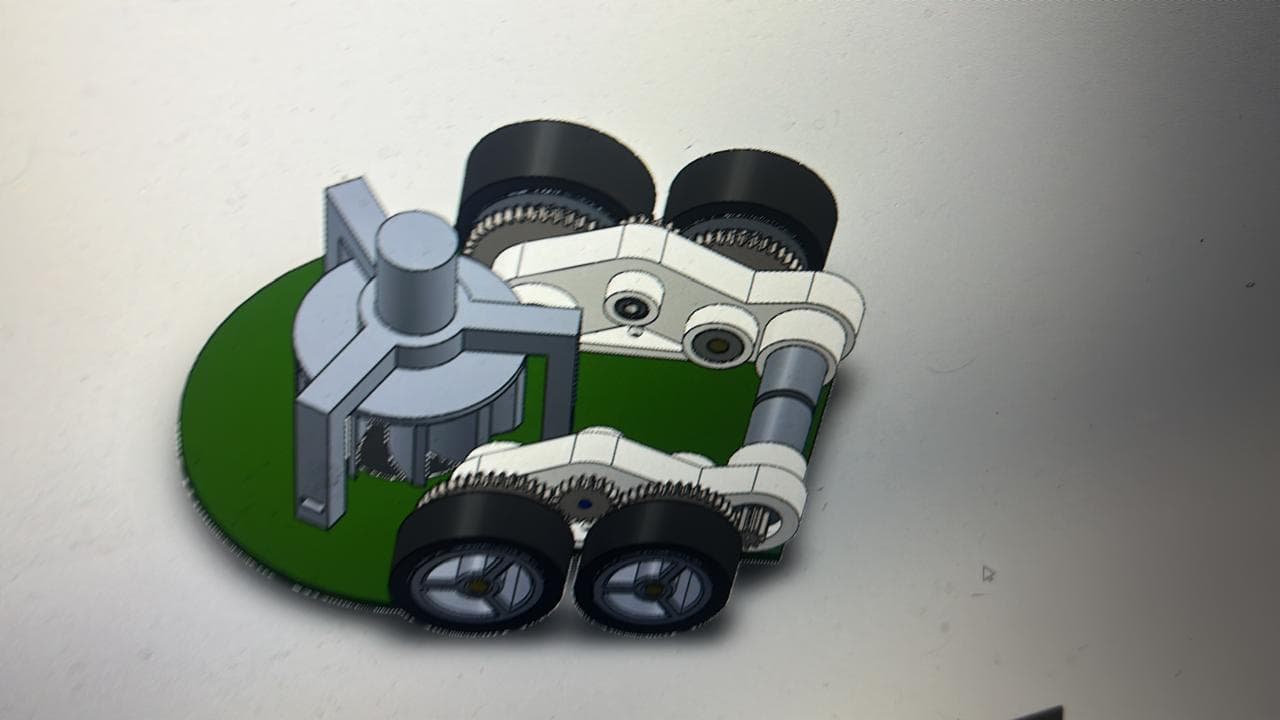
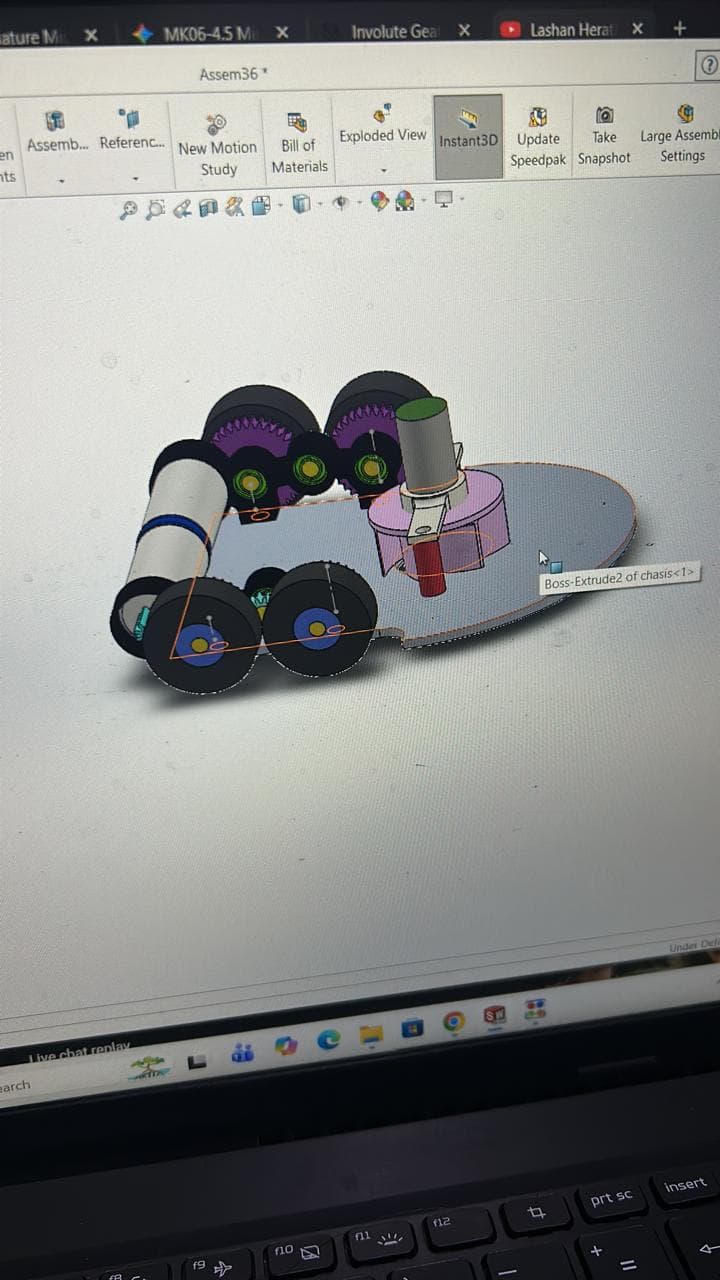
Designed a compact, lightweight micromouse robot using coreless motors, focusing on precision mechanical design, optimized component placement, and high-speed maze navigation.
Loading
3D modeling and mechanical design using CAD tools for robotics and engineering projects.
Subject
Designed a compact, lightweight micromouse robot using coreless motors, focusing on precision mechanical design, optimized component placement, and high-speed maze navigation.
Subject
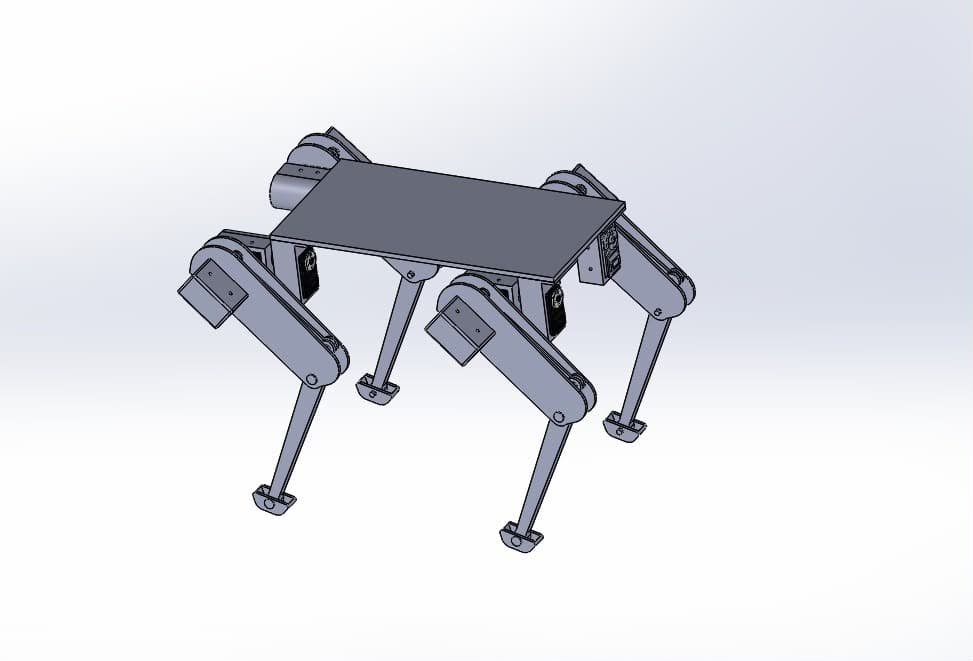
Designed a quadruped robot dog with 12 motors (3 degrees of freedom per leg), focusing on 3D-printed mechanical structures, joint integration, and coordinated leg movement for robotic locomotion.
Subject
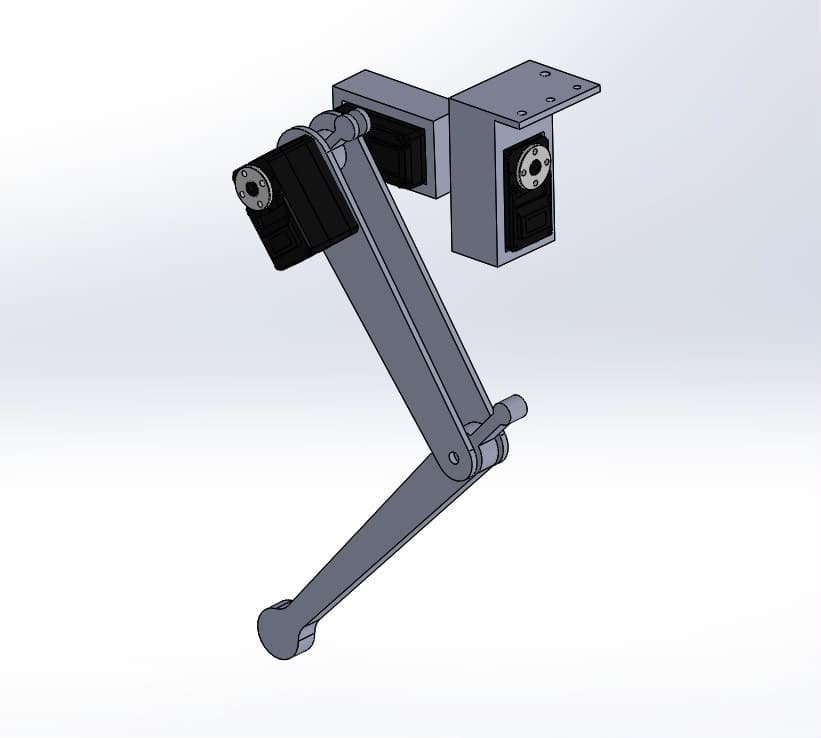
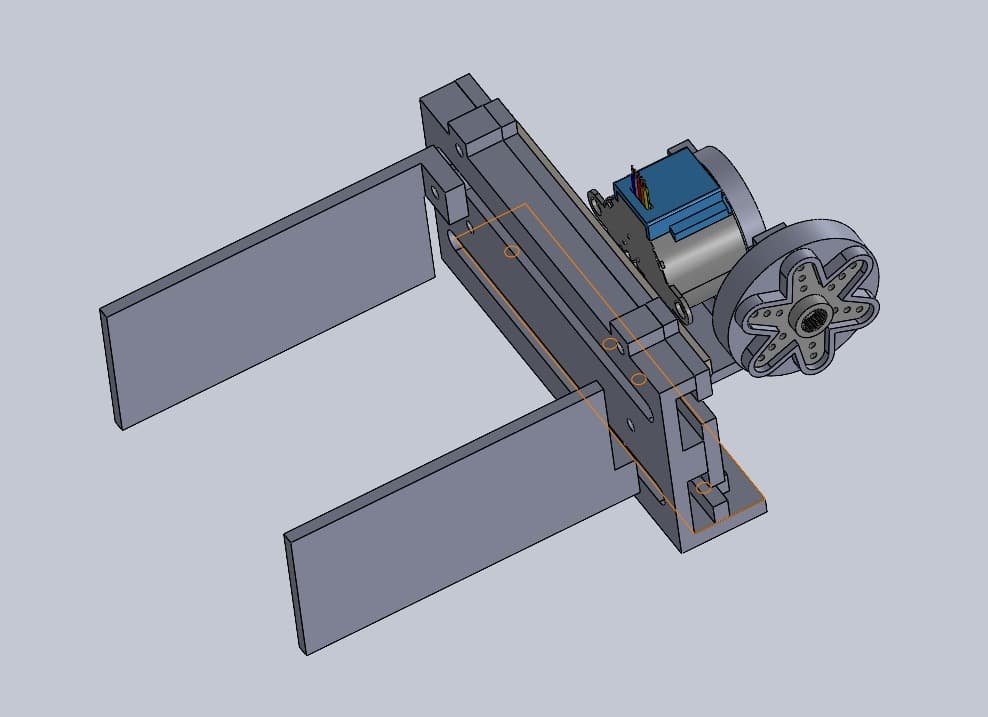
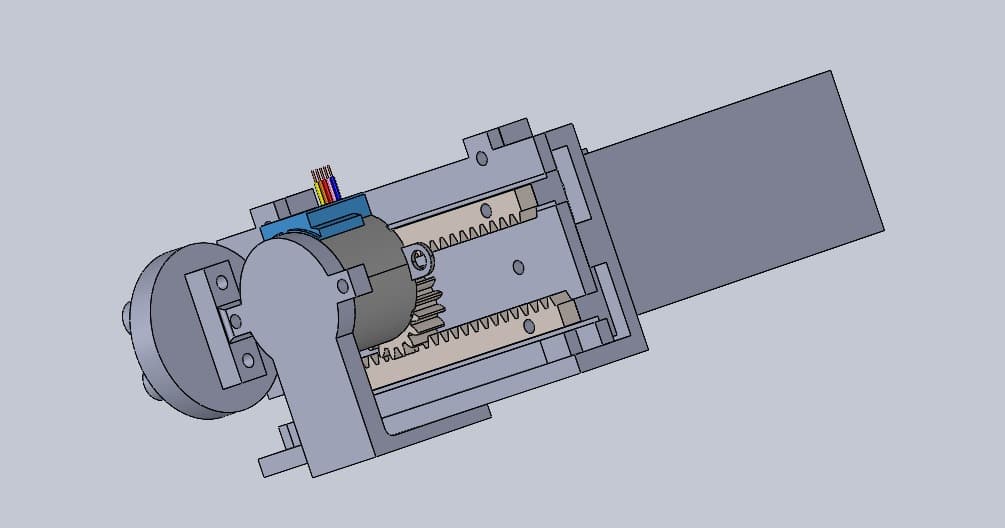
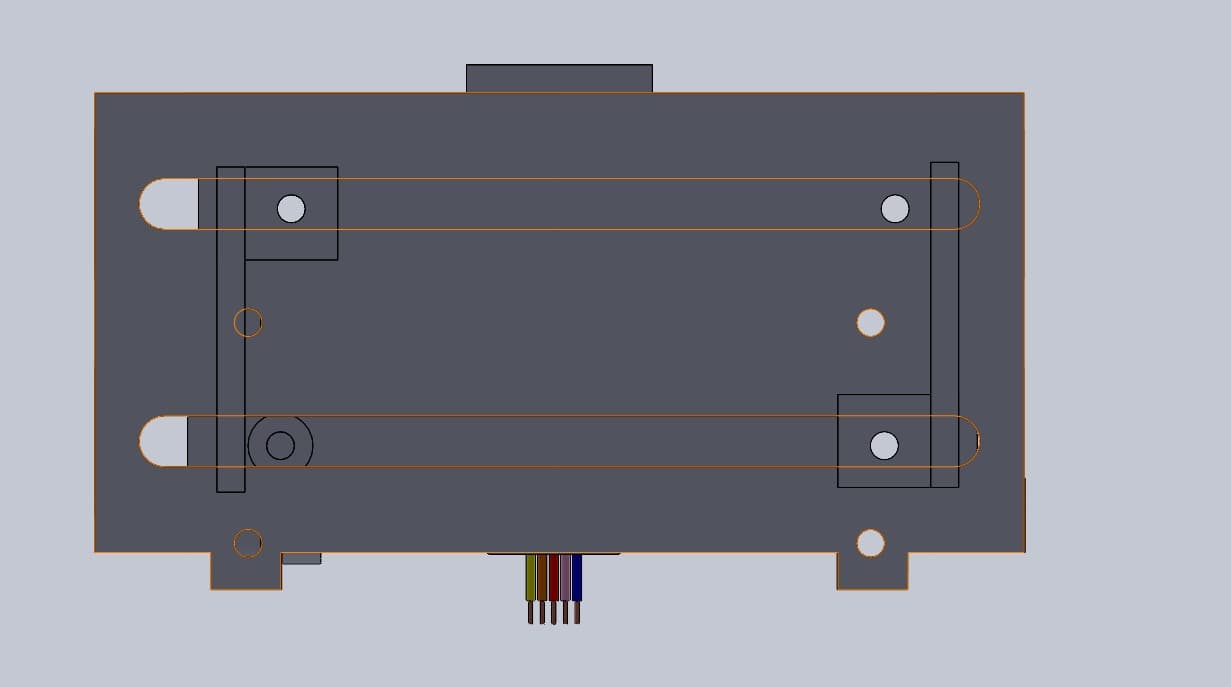
Designed a 3D-printed robotic arm with a gripper mechanism for grasping, lifting, and handling boxes, focusing on mechanical design, joint integration, and reliable object manipulation.
Subject
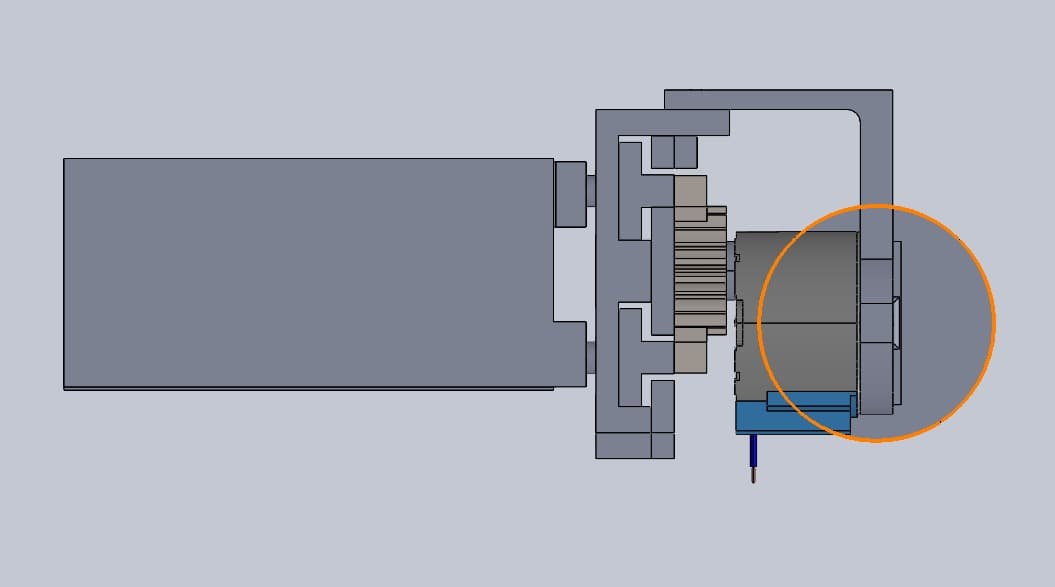
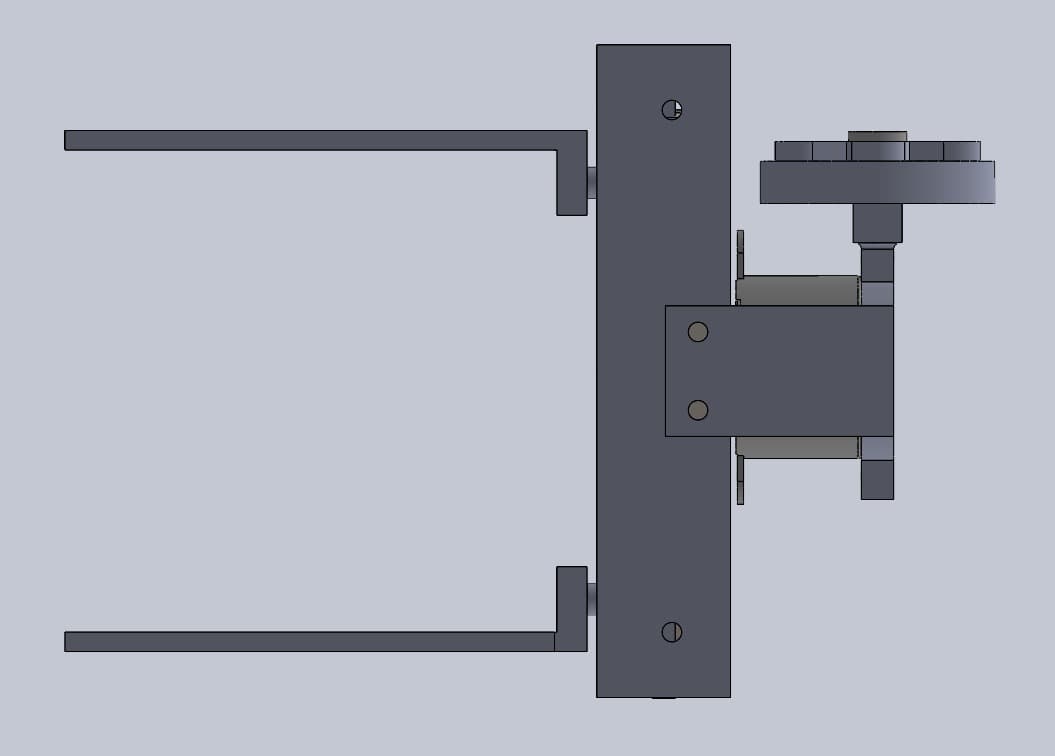
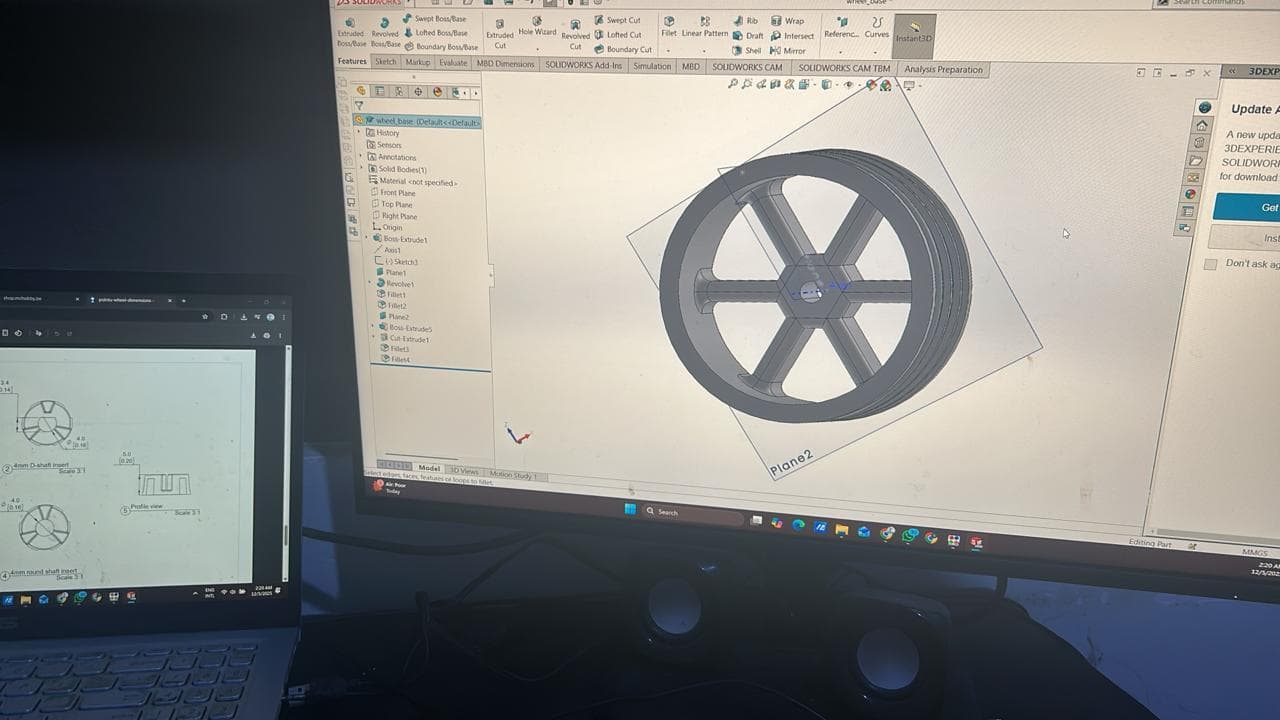
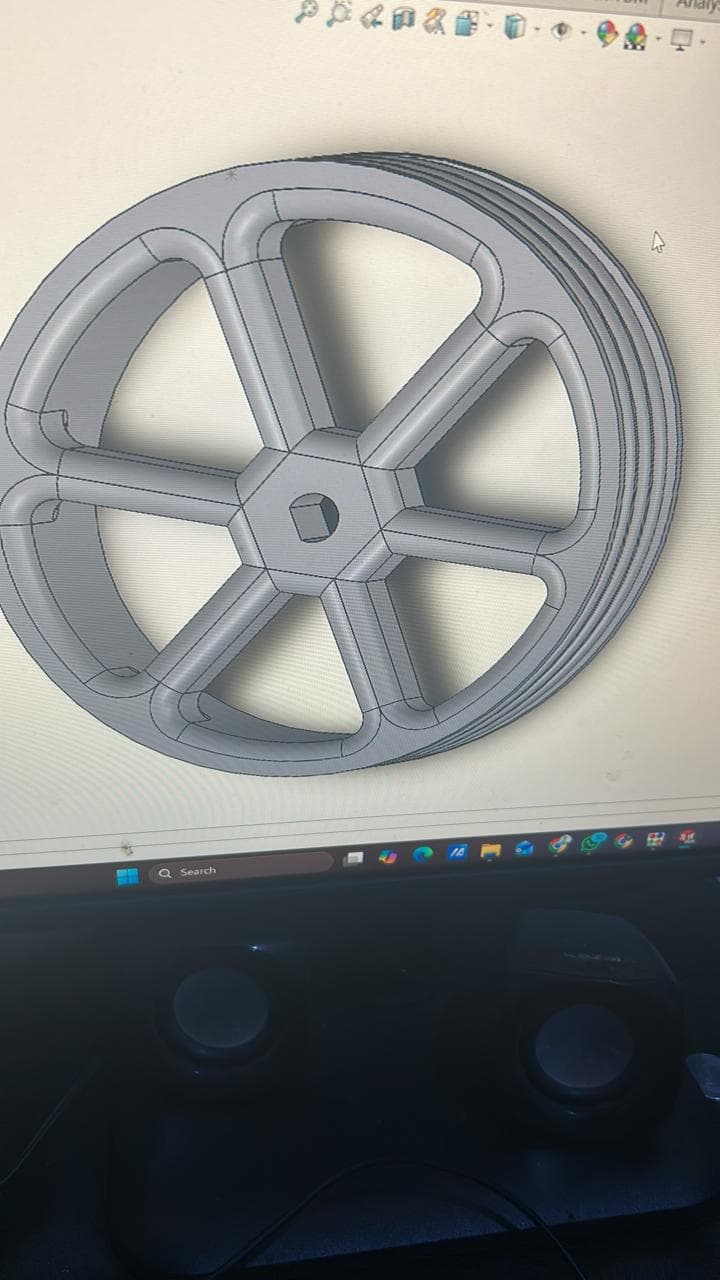
esigned a custom wheel using CAD software, focusing on lightweight structural geometry, hub integration, and mechanical strength for autonomous robot mobility.
Subject
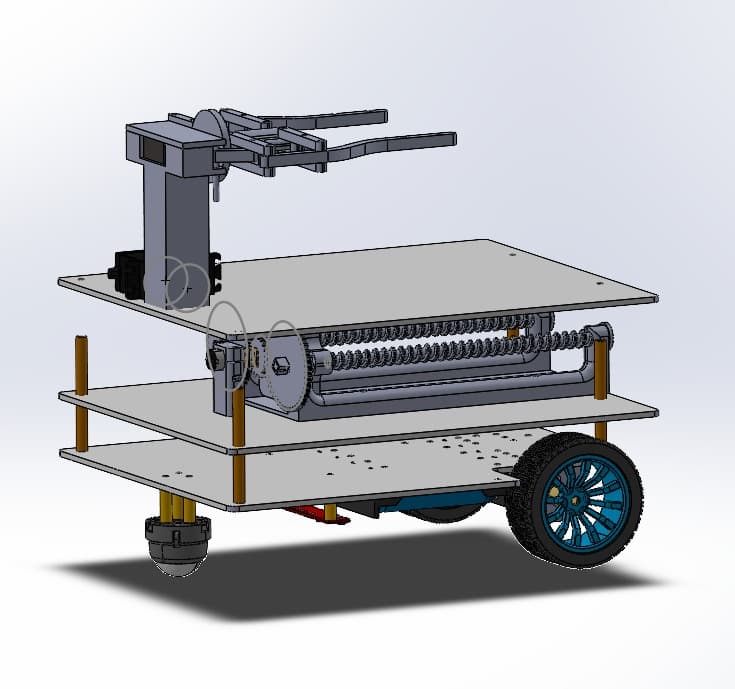
Designed and assembled a competition robot using 3D CAD modelling, integrating the chassis, wheel system, mechanical lifting mechanism, and robotic gripper for object handling and autonomous operation.